 |
Parasol Planning Library (PPL)
|
|
Parasol Planning Library (PPL)
|
#include <GroupLocalPlan.h>
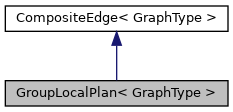
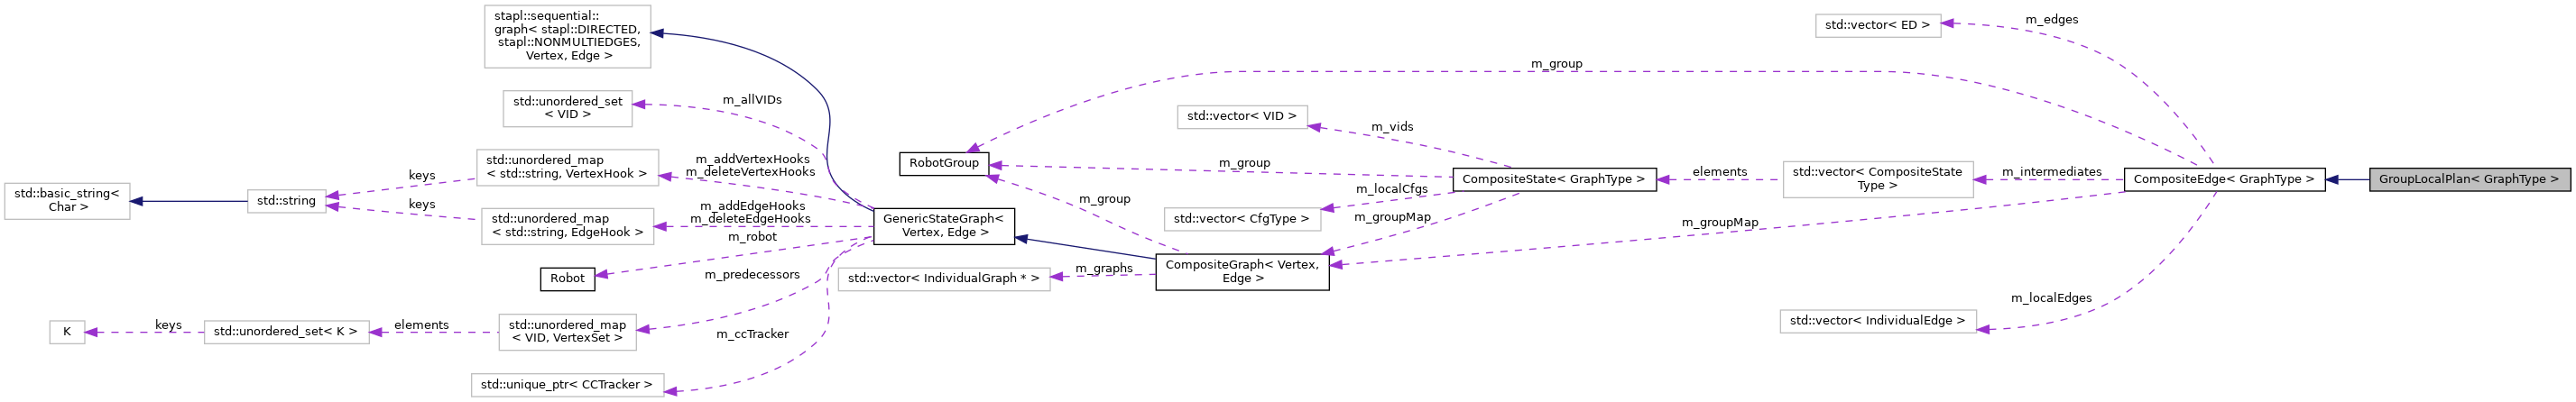
Public Types | |
Local Types | |
| typedef CompositeEdge< GraphType > | BaseType |
| typedef BaseType::GroupGraphType | GroupGraphType |
| typedef GraphType::CfgType | CfgType |
| typedef GraphType::EdgeType | IndividualEdge |
| typedef double | EdgeWeight |
| typedef GroupCfg< GraphType > | GroupCfgType |
| typedef GroupRoadmap< GroupCfgType, GroupLocalPlan > | GroupRoadmapType |
| typedef std::vector< GroupCfgType > | GroupCfgPath |
| typedef BaseType::CompositePath | CompositePath |
| typedef stapl::edge_descriptor_impl< size_t > | ED |
| typedef std::vector< size_t > | Formation |
 Public Types inherited from CompositeEdge< GraphType > | |
| typedef GraphType::CfgType | IndividualCfg |
| typedef GraphType::EdgeType | IndividualEdge |
| typedef double | EdgeWeight |
| typedef stapl::edge_descriptor_impl< size_t > | ED |
| typedef CompositeState< GraphType > | CompositeStateType |
| typedef CompositeGraph< CompositeStateType, CompositeEdge > | GroupGraphType |
| typedef std::vector< CompositeStateType > | CompositePath |
| typedef std::vector< ED >::iterator | iterator |
| typedef std::vector< ED >::const_iterator | const_iterator |
Public Member Functions | |
Construction | |
| GroupLocalPlan (GroupRoadmapType *const &_g=nullptr, const std::string &_lpLabel="", const double _w=0.0, const GroupCfgPath &_path=GroupCfgPath()) | |
| GroupLocalPlan (RobotGroup *const &_g, const std::string &_lpLabel="", const double _w=0.0, const GroupCfgPath &_path=GroupCfgPath()) | |
| virtual | ~GroupLocalPlan ()=default |
Misc. Interface Functions | |
| void | SetGroupRoadmap (GroupRoadmapType *const &_g) |
| void | SetFormation (const Formation &_indices) |
| const Formation & | GetFormation () const noexcept |
| void | Clear () noexcept |
| Reset the states of this object. More... | |
| GroupCfgPath & | GetIntermediates () noexcept |
| Get the group configuration intermediates. More... | |
| const GroupCfgPath & | GetIntermediates () const noexcept |
| Get the group configuration intermediates. More... | |
| void | SetIntermediates (const GroupCfgPath &_cfgs) |
| Set the group configuration intermediates. More... | |
| const std::string & | GetLPLabel () const noexcept |
| Get the string label of this current local plan. More... | |
| void | SetLPLabel (const std::string _label) noexcept |
Stapl graph interface | |
| virtual GroupLocalPlan | operator+ (const GroupLocalPlan &_other) const |
| Public Member Functions inherited from CompositeEdge< GraphType > | |
| CompositeEdge (GroupGraphType *const &_g=nullptr, const double _w=0.0, const CompositePath &_intermediates=CompositePath()) | |
| CompositeEdge (RobotGroup *const &_g, const double _w=0.0, const CompositePath &_intermediates=CompositePath()) | |
| virtual bool | operator== (const CompositeEdge &_w) const noexcept |
| virtual bool | operator!= (const CompositeEdge &_w) const noexcept |
| virtual bool | operator< (const CompositeEdge &_other) const noexcept |
| virtual EdgeWeight | GetWeight () const noexcept |
| Get the numeric weight for this edge. More... | |
| virtual void | SetWeight (const EdgeWeight _w) noexcept |
| void | SetGroupGraph (GroupGraphType *const &_g) |
| CompositePath & | GetIntermediates () noexcept |
| Get the composite state intermediates. More... | |
| const CompositePath & | GetIntermediates () const noexcept |
| Get the composite state intermediates. More... | |
| const size_t | GetNumIntermediates () noexcept |
| Get the number of composite intermediates along this edge. More... | |
| void | SetIntermediates (const CompositePath &_cfgs) |
| Set the composite state intermediates. More... | |
| virtual void | Write (std::ostream &_os) const |
| virtual void | SetEdge (Robot *const _robot, const ED _ed) |
| void | SetEdge (const size_t _robot, IndividualEdge &&_edge) |
| void | SetEdge (Robot *const _robot, IndividualEdge &&_edge) |
| virtual IndividualEdge * | GetEdge (Robot *const _robot) |
| virtual const IndividualEdge * | GetEdge (Robot *const _robot) const |
| virtual IndividualEdge * | GetEdge (const size_t _robotIndex) |
| virtual const IndividualEdge * | GetEdge (const size_t _robotIndex) const |
| std::vector< IndividualEdge > & | GetLocalEdges () noexcept |
| Get a vector of local edges in the plan. More... | |
| void | ClearLocalEdges () noexcept |
| Clear all local edges in the plan. More... | |
| virtual std::vector< ED > & | GetEdgeDescriptors () noexcept |
| virtual size_t | GetNumRobots () const noexcept |
| Get the number of robots given in this group local plan. More... | |
| virtual std::unordered_set< Robot * > | GetActiveRobots () |
| virtual void | SetTimeSteps (size_t _timesteps) |
| Set the number of timesteps along this composite edge. More... | |
| virtual size_t | GetTimeSteps () const |
| Get the number of timesteps along this composite edge. More... | |
| virtual CompositeEdge | operator+ (const CompositeEdge &_other) const |
| virtual double | Weight () const noexcept |
| Get the weight of the plan. More... | |
| virtual iterator | begin () noexcept |
| virtual iterator | end () noexcept |
| virtual const_iterator | begin () const noexcept |
| virtual const_iterator | end () const noexcept |
Additional Inherited Members | |
| Protected Attributes inherited from CompositeEdge< GraphType > | |
| GroupGraphType * | m_groupMap {nullptr} |
| The composite graph that this edge is in. More... | |
| RobotGroup * | m_group {nullptr} |
| The robot group that this edge belongs to. More... | |
| double | m_weight {std::numeric_limits<double>::infinity()} |
| The edge weight. More... | |
| CompositePath | m_intermediates |
| Composite state intermediates. More... | |
| std::vector< ED > | m_edges |
| Descriptors of the individual edges. More... | |
| std::vector< IndividualEdge > | m_localEdges |
| Note that any edges added to m_localEdges must be valid and complete. More... | |
| size_t | m_timesteps |
| The number of timesteps along this edge. More... | |
A local plan for multiple robots. Each robot will be executing this motion simultaneously, and the total time is the same for each robot.
| typedef CompositeEdge<GraphType> GroupLocalPlan< GraphType >::BaseType |
| typedef GraphType::CfgType GroupLocalPlan< GraphType >::CfgType |
| typedef BaseType::CompositePath GroupLocalPlan< GraphType >::CompositePath |
| typedef stapl::edge_descriptor_impl<size_t> GroupLocalPlan< GraphType >::ED |
| typedef double GroupLocalPlan< GraphType >::EdgeWeight |
| typedef std::vector<size_t> GroupLocalPlan< GraphType >::Formation |
A formation represents a group of robots which are maintaining their configurations relative to a leader, such as maintaining a square or V-shape while moving. The values are robot indexes (within the group, not problem) with the first index denoting the leader robot.
| typedef std::vector<GroupCfgType> GroupLocalPlan< GraphType >::GroupCfgPath |
| typedef GroupCfg<GraphType> GroupLocalPlan< GraphType >::GroupCfgType |
| typedef BaseType::GroupGraphType GroupLocalPlan< GraphType >::GroupGraphType |
| typedef GroupRoadmap<GroupCfgType, GroupLocalPlan> GroupLocalPlan< GraphType >::GroupRoadmapType |
| typedef GraphType::EdgeType GroupLocalPlan< GraphType >::IndividualEdge |
| GroupLocalPlan< GraphType >::GroupLocalPlan | ( | GroupRoadmapType *const & | _g = nullptr, |
| const std::string & | _lpLabel = "", |
||
| const double | _w = 0.0, |
||
| const GroupCfgPath & | _path = GroupCfgPath() |
||
| ) |
Constructs a GroupLocalPlan.
| _g | The group roadmap in which this edge exists. |
| _lpLabel | The string label to assign to this plan. Defaults to empty string. |
| _w | The weight of the plan. Defaults to 0.0. |
| _path | The path to be given by the plan. Defaults to GroupCfgPath(). |
| GroupLocalPlan< GraphType >::GroupLocalPlan | ( | RobotGroup *const & | _g, |
| const std::string & | _lpLabel = "", |
||
| const double | _w = 0.0, |
||
| const GroupCfgPath & | _path = GroupCfgPath() |
||
| ) |
Constructs a GroupLocalPlan.
| _g | The robot group for which this edge exists. |
| _lpLabel | The string label to assign to this plan. Defaults to empty string. |
| _w | The weight of the plan. Defaults to 0.0. |
| _path | The path to be given by the plan. Defaults to GroupCfgPath(). |
|
virtualdefault |
|
virtualnoexcept |
Reset the states of this object.
Reimplemented from CompositeEdge< GraphType >.
|
noexcept |
Get the formation of the robots. The first index is the leader.
|
noexcept |
Get the group configuration intermediates.
|
noexcept |
Get the group configuration intermediates.
|
noexcept |
Get the string label of this current local plan.
|
virtual |
Add two group local plans. This only adds weights, it doesn't take intermediates into account.
| void GroupLocalPlan< GraphType >::SetFormation | ( | const Formation & | _indices | ) |
Set the formation of the robots. The first index is the leader.
| _indices | The vector of robot indices given. |
| void GroupLocalPlan< GraphType >::SetGroupRoadmap | ( | GroupRoadmapType *const & | _g | ) |
Set the group roadmap to which this plan belongs.
| _g | The given group roadmap. |
| void GroupLocalPlan< GraphType >::SetIntermediates | ( | const GroupCfgPath & | _cfgs | ) |
Set the group configuration intermediates.
|
noexcept |
Set the string label of this current local plan.
| _label | The desired string label. |
 1.9.1