|
|
| | LPSweptDistance (string _lpLabel="sl", double _positionRes=0.1, double _orientationRes=0.1, bool _bbox=false) |
| |
| | LPSweptDistance (XMLNode &_node) |
| |
| virtual | ~LPSweptDistance ()=default |
| |
|
| virtual void | Print (std::ostream &_os) const override |
| |
|
| virtual double | Distance (const Cfg &_c1, const Cfg &_c2) override |
| |
| | DistanceMetricMethod ()=default |
| |
| | DistanceMetricMethod (XMLNode &_node) |
| |
| virtual | ~DistanceMetricMethod ()=default |
| |
| virtual double | Distance (const GroupCfgType &_c1, const GroupCfgType &_c2) |
| |
| double | EdgeWeight (const RoadmapType *const _r, const typename RoadmapType::CEI &_edge) noexcept |
| |
| double | EdgeWeight (const RoadmapType *const _r, const VID _source, const VID _target) noexcept |
| |
| virtual void | ScaleCfg (double _length, Cfg &_c, const Cfg &_o) |
| |
| void | ScaleCfg (double _length, Cfg &_c) |
| |
| virtual void | ScaleCfg (double _length, GroupCfgType &_c, const GroupCfgType &_o) |
| |
| void | ScaleCfg (double _length, GroupCfgType &_c) |
| |
| | MPBaseObject (const std::string &_label="", const std::string &_name="", bool _debug=false) |
| |
| | MPBaseObject (XMLNode &_node) |
| |
| virtual | ~MPBaseObject () |
| |
| virtual void | Initialize () |
| |
| const std::string & | GetName () const |
| | Get the class name for this object. More...
|
| |
| const std::string & | GetLabel () const |
| | Get the unique label for this object. More...
|
| |
| std::string | GetNameAndLabel () const |
| | Get the unique string identifier for this object "m_name::m_label". More...
|
| |
| void | SetLabel (const std::string &) |
| | Set the unique label for this object. More...
|
| |
| void | SetMPLibrary (MPLibrary *) noexcept |
| | Set the owning MPLibrary. More...
|
| |
| MPLibrary * | GetMPLibrary () const noexcept |
| | Get the owning MPLibrary. More...
|
| |
| bool | IsRunning () const noexcept |
| | Check the library's running flag. More...
|
| |
| MPProblem * | GetMPProblem () const noexcept |
| | Get the library's current MPProblem. More...
|
| |
| Environment * | GetEnvironment () const noexcept |
| | Get the current environment. More...
|
| |
| MPTask * | GetTask () const noexcept |
| | Get the current task. More...
|
| |
| GroupTask * | GetGroupTask () const noexcept |
| | Get the current group task. More...
|
| |
| MPSolutionType * | GetMPSolution () const noexcept |
| |
| RoadmapType * | GetRoadmap (Robot *const _r=nullptr) const noexcept |
| | Get the current free-space roadmap. More...
|
| |
| GroupRoadmapType * | GetGroupRoadmap (RobotGroup *const _g=nullptr) const noexcept |
| | Get the current free-space group roadmap. More...
|
| |
| RoadmapType * | GetBlockRoadmap (Robot *const _r=nullptr) const noexcept |
| | Get the current obstacle-space roadmap. More...
|
| |
| Path * | GetPath (Robot *const _r=nullptr) const noexcept |
| |
| GroupPath * | GetGroupPath (RobotGroup *const _g=nullptr) const noexcept |
| | Get the current best group path. More...
|
| |
| StatClass * | GetStatClass () const noexcept |
| | Get the current StatClass. More...
|
| |
| LocalObstacleMap * | GetLocalObstacleMap () const noexcept |
| | Get the local obstacle map. More...
|
| |
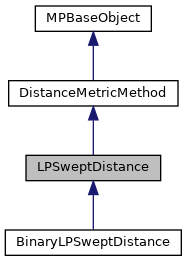
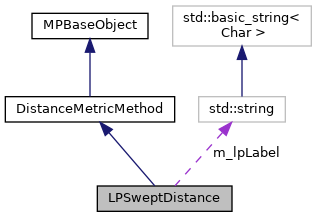
Measures the distance swept by a robot when moving between two configurations. The distance is the summed vertex displacements along the path generated by the LocalPlanner.
 Public Types inherited from DistanceMetricMethod
 1.9.1