 |
Parasol Planning Library (PPL)
|
|
Parasol Planning Library (PPL)
|
Base algorithm abstraction for PathModifiers. More...
#include <PathModifierMethod.h>
Public Types | |
Motion Planning Types | |
| typedef MPBaseObject::RoadmapType | RoadmapType |
| typedef RoadmapType::VID | VID |
 Public Types inherited from MPBaseObject | |
| typedef DefaultWeight< Cfg > | WeightType |
| typedef GenericStateGraph< Cfg, WeightType > | RoadmapType |
| typedef GroupCfg< RoadmapType > | GroupCfgType |
| typedef GroupLocalPlan< RoadmapType > | GroupWeightType |
| typedef GroupRoadmap< GroupCfgType, GroupWeightType > | GroupRoadmapType |
Public Member Functions | |
Construction | |
| PathModifierMethod ()=default | |
| PathModifierMethod (XMLNode &_node) | |
| virtual | ~PathModifierMethod ()=default |
MPBaseObject Overrides | |
| virtual void | Print (ostream &_os) const override |
| Public Member Functions inherited from MPBaseObject | |
| MPBaseObject (const std::string &_label="", const std::string &_name="", bool _debug=false) | |
| MPBaseObject (XMLNode &_node) | |
| virtual | ~MPBaseObject () |
| virtual void | Initialize () |
| const std::string & | GetName () const |
| Get the class name for this object. More... | |
| const std::string & | GetLabel () const |
| Get the unique label for this object. More... | |
| std::string | GetNameAndLabel () const |
| Get the unique string identifier for this object "m_name::m_label". More... | |
| void | SetLabel (const std::string &) |
| Set the unique label for this object. More... | |
| void | SetMPLibrary (MPLibrary *) noexcept |
| Set the owning MPLibrary. More... | |
| MPLibrary * | GetMPLibrary () const noexcept |
| Get the owning MPLibrary. More... | |
| bool | IsRunning () const noexcept |
| Check the library's running flag. More... | |
| MPProblem * | GetMPProblem () const noexcept |
| Get the library's current MPProblem. More... | |
| Environment * | GetEnvironment () const noexcept |
| Get the current environment. More... | |
| MPTask * | GetTask () const noexcept |
| Get the current task. More... | |
| GroupTask * | GetGroupTask () const noexcept |
| Get the current group task. More... | |
| MPSolutionType * | GetMPSolution () const noexcept |
| RoadmapType * | GetRoadmap (Robot *const _r=nullptr) const noexcept |
| Get the current free-space roadmap. More... | |
| GroupRoadmapType * | GetGroupRoadmap (RobotGroup *const _g=nullptr) const noexcept |
| Get the current free-space group roadmap. More... | |
| RoadmapType * | GetBlockRoadmap (Robot *const _r=nullptr) const noexcept |
| Get the current obstacle-space roadmap. More... | |
| Path * | GetPath (Robot *const _r=nullptr) const noexcept |
| GroupPath * | GetGroupPath (RobotGroup *const _g=nullptr) const noexcept |
| Get the current best group path. More... | |
| StatClass * | GetStatClass () const noexcept |
| Get the current StatClass. More... | |
| LocalObstacleMap * | GetLocalObstacleMap () const noexcept |
| Get the local obstacle map. More... | |
PathModifier Interface | |
| virtual void | Modify (vector< Cfg > &_path, vector< Cfg > &_newPath) |
| virtual void | Modify (RoadmapType *_graph, vector< Cfg > &_path, vector< Cfg > &_newPath) |
| virtual bool | ModifyImpl (RoadmapType *_graph, vector< Cfg > &_path, vector< Cfg > &_newPath)=0 |
| void | AddToPath (vector< Cfg > &_path, LPOutput *_lpOutput, Cfg &_end) |
| vector< VID > | GetPathVIDs (vector< Cfg > &_path, RoadmapType *_graph) |
| void | RemoveBranches (const string &_dmLabel, vector< Cfg > &_path, vector< Cfg > &_newPath) |
| @TODO Figure out what this does and document it. More... | |
Additional Inherited Members | |
| Protected Member Functions inherited from MPBaseObject | |
| void | SetName (const std::string &_s) |
| const std::string & | GetBaseFilename () const |
| Protected Attributes inherited from MPBaseObject | |
| bool | m_debug |
| Print debug info? More... | |
Base algorithm abstraction for PathModifiers.
PathModifierMethod has one main method, Modify, which takes an input path and produces a valid output path.
|
default |
| PathModifierMethod::PathModifierMethod | ( | XMLNode & | _node | ) |
|
virtualdefault |
|
protected |
|
virtual |
Modifies the input path to a new valid path
| _path | A path of configurations within a resolution distance of each other |
| _newPath | An empty vector to place the resulting modified path |
@usage
|
protectedpure virtual |
Modifies the input path to a new valid path
| _path | A path of configurations within a resolution distance of each other |
| _newPath | An empty vector to place the resulting modified path |
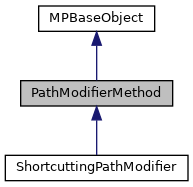
Implemented in ShortcuttingPathModifier.
|
overridevirtual |
Print internal state of this object.
| _os | The std::ostream to print to. |
Reimplemented from MPBaseObject.
Reimplemented in ShortcuttingPathModifier.
|
protected |
@TODO Figure out what this does and document it.
 1.9.1