|
|
| | RewireConnector () |
| |
| | RewireConnector (XMLNode &_node) |
| |
| virtual | ~RewireConnector ()=default |
| |
| | ConnectorMethod () |
| |
| | ConnectorMethod (XMLNode &_node) |
| |
| virtual | ~ConnectorMethod ()=default |
| |
| virtual void | Print (std::ostream &_os) const override |
| |
| virtual void | Initialize () override |
| |
| template<typename AbstractRoadmapType > |
| void | Connect (AbstractRoadmapType *const _r, const VertexSet *const _targetSet=nullptr, OutputIterator< AbstractRoadmapType > *const _collision=nullptr) |
| |
| template<typename AbstractRoadmapType > |
| void | Connect (AbstractRoadmapType *const _r, const VID _source, const VertexSet *const _targetSet=nullptr, OutputIterator< AbstractRoadmapType > *const _collision=nullptr) |
| |
| template<typename AbstractRoadmapType , typename InputIterator > |
| void | Connect (AbstractRoadmapType *const _r, InputIterator _sourceBegin, InputIterator _sourceEnd, const VertexSet *const _targetSet=nullptr, OutputIterator< AbstractRoadmapType > *const _collision=nullptr) |
| |
| bool | IsRewiring () const noexcept |
| |
| | MPBaseObject (const std::string &_label="", const std::string &_name="", bool _debug=false) |
| |
| | MPBaseObject (XMLNode &_node) |
| |
| virtual | ~MPBaseObject () |
| |
| const std::string & | GetName () const |
| | Get the class name for this object. More...
|
| |
| const std::string & | GetLabel () const |
| | Get the unique label for this object. More...
|
| |
| std::string | GetNameAndLabel () const |
| | Get the unique string identifier for this object "m_name::m_label". More...
|
| |
| void | SetLabel (const std::string &) |
| | Set the unique label for this object. More...
|
| |
| void | SetMPLibrary (MPLibrary *) noexcept |
| | Set the owning MPLibrary. More...
|
| |
| MPLibrary * | GetMPLibrary () const noexcept |
| | Get the owning MPLibrary. More...
|
| |
| bool | IsRunning () const noexcept |
| | Check the library's running flag. More...
|
| |
| MPProblem * | GetMPProblem () const noexcept |
| | Get the library's current MPProblem. More...
|
| |
| Environment * | GetEnvironment () const noexcept |
| | Get the current environment. More...
|
| |
| MPTask * | GetTask () const noexcept |
| | Get the current task. More...
|
| |
| GroupTask * | GetGroupTask () const noexcept |
| | Get the current group task. More...
|
| |
| MPSolutionType * | GetMPSolution () const noexcept |
| |
| RoadmapType * | GetRoadmap (Robot *const _r=nullptr) const noexcept |
| | Get the current free-space roadmap. More...
|
| |
| GroupRoadmapType * | GetGroupRoadmap (RobotGroup *const _g=nullptr) const noexcept |
| | Get the current free-space group roadmap. More...
|
| |
| RoadmapType * | GetBlockRoadmap (Robot *const _r=nullptr) const noexcept |
| | Get the current obstacle-space roadmap. More...
|
| |
| Path * | GetPath (Robot *const _r=nullptr) const noexcept |
| |
| GroupPath * | GetGroupPath (RobotGroup *const _g=nullptr) const noexcept |
| | Get the current best group path. More...
|
| |
| StatClass * | GetStatClass () const noexcept |
| | Get the current StatClass. More...
|
| |
| LocalObstacleMap * | GetLocalObstacleMap () const noexcept |
| | Get the local obstacle map. More...
|
| |
|
| template<typename AbstractRoadmapType > |
| void | ConnectNeighbors (AbstractRoadmapType *const _r, const VID _source, const std::vector< Neighbor > &_neighbors, OutputIterator< AbstractRoadmapType > *const _collision=nullptr, const bool _earlyQuit=false) |
| |
| bool | ConnectNodes (RoadmapType *const _r, const VID _source, const VID _target, OutputIterator< RoadmapType > *const _collision=nullptr) |
| |
| bool | ConnectNodes (GroupRoadmapType *const _r, const VID _source, const VID _target, OutputIterator< GroupRoadmapType > *const _collision=nullptr) |
| |
| template<typename AbstractRoadmapType > |
| bool | DoNotCheck (AbstractRoadmapType *const _r, const VID _source, const VID _target) const |
| |
| void | CacheFailedConnection (void *const _map, const VID _source, const VID _target) noexcept |
| |
| bool | IsCached (void *const _map, const VID _source, const VID _target) const noexcept |
| |
| void | ClearConnectionAttempts () |
| | Clear the attempts cache. More...
|
| |
| void | SetName (const std::string &_s) |
| |
| const std::string & | GetBaseFilename () const |
| |
| ConnectionAttemptsCache | m_attemptsCache |
| | All failed connection attempts. More...
|
| |
| std::string | m_lpLabel |
| | Local Planner. More...
|
| |
| bool | m_skipIfSameCC {true} |
| | Skip connections within the same CC? More...
|
| |
| size_t | m_maxFailures {0} |
| | Maximum allowed failures per use. More...
|
| |
| size_t | m_failures {0} |
| | Failures in this use. More...
|
| |
| bool | m_oneWay {false} |
| | Create one-way edges or two-way? More...
|
| |
| bool | m_rewiring {false} |
| | Does this connector delete edges? More...
|
| |
| bool | m_selfEdges {false} |
| | Indicates if roadmap vertices should have self-edges. More...
|
| |
| std::vector< Neighbor > | m_neighborBuffer |
| |
| bool | m_debug |
| | Print debug info? More...
|
| |
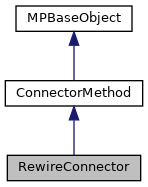
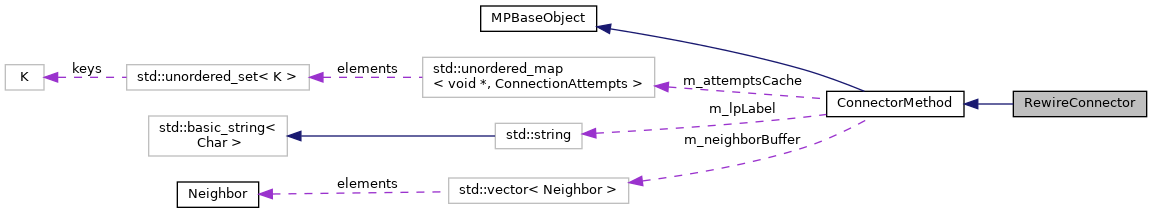
Re-wires a tree for optimal RRT planners. This only makes sense for tree-like planners. It will change the structure of the tree; ensure that your algorithm can handle this before using.
Reference: Sertac Karaman and Emilio Frazzoli. "Sampling-based algorithms for optimal
motion planning". IJRR 2011.
 Public Member Functions inherited from ConnectorMethod
 1.9.1