Parasol Planning Library (PPL)
ObstacleBasedSampler Class Reference

Obstacle-based sampling. More...

#include <ObstacleBasedSampler.h>

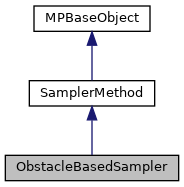
Inheritance diagram for ObstacleBasedSampler:
Inheritance graph
[legend]
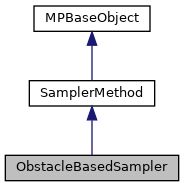
Collaboration diagram for ObstacleBasedSampler:
Collaboration graph
[legend]

Public Types

Motion Planning Types
typedef MPBaseObject::GroupCfgType GroupCfgType
 
typedef std::map< Robot *, const Boundary * > BoundaryMap
 
- Public Types inherited from SamplerMethod
typedef MPBaseObject::GroupCfgType GroupCfgType
 
typedef std::vector< Cfg >::iterator InputIterator
 
typedef std::back_insert_iterator< std::vector< Cfg > > OutputIterator
 
typedef std::vector< GroupCfgType >::iterator GroupInputIterator
 
typedef std::back_insert_iterator< std::vector< GroupCfgType > > GroupOutputIterator
 
typedef std::map< Robot *, const Boundary * > BoundaryMap
 A map from robots to sampling boundaries. More...
 
- Public Types inherited from MPBaseObject
typedef DefaultWeight< Cfg > WeightType
 
typedef GenericStateGraph< Cfg, WeightType > RoadmapType
 
typedef GroupCfg< RoadmapType > GroupCfgType
 
typedef GroupLocalPlan< RoadmapType > GroupWeightType
 
typedef GroupRoadmap< GroupCfgType, GroupWeightType > GroupRoadmapType
 

Public Member Functions

Construction
 ObstacleBasedSampler (string _vcLabel="", string _dmLabel="", int _free=1, int _coll=0, double _step=0, bool _useBBX=true, string _pointSelection="cspace")
 
 ObstacleBasedSampler (XMLNode &_node)
 
virtual ~ObstacleBasedSampler ()=default
 
MPBaseObject Overrides
virtual void Print (ostream &_os) const override
 
- Public Member Functions inherited from SamplerMethod
 SamplerMethod ()=default
 
 SamplerMethod (XMLNode &_node)
 
virtual ~SamplerMethod ()=0
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const Boundary *const _boundary, OutputIterator _valid, OutputIterator _invalid)
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const Boundary *const _boundary, OutputIterator _valid)
 This is an overloaded member function, provided for convenience. It differs from the above function only in what argument(s) it accepts. More...
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const Boundary *const _robotBoundary, const Boundary *const _eeBoundary, OutputIterator _valid, OutputIterator _invalid)
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const Boundary *const _robotBoundary, const Boundary *const _eeBoundary, OutputIterator _valid)
 
virtual void Filter (InputIterator _first, InputIterator _last, size_t _maxAttempts, const Boundary *const _boundary, OutputIterator _valid, OutputIterator _invalid)
 
void Filter (InputIterator _first, InputIterator _last, size_t _maxAttempts, const Boundary *const _boundary, OutputIterator _valid)
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const Boundary *const _boundary, GroupOutputIterator _valid, GroupOutputIterator _invalid)
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const Boundary *const _boundary, GroupOutputIterator _valid)
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const BoundaryMap &_boundary, GroupOutputIterator _valid, GroupOutputIterator _invalid)
 
virtual void Sample (size_t _numNodes, size_t _maxAttempts, const BoundaryMap &_boundary, GroupOutputIterator _valid)
 
virtual void Filter (GroupInputIterator _first, GroupInputIterator _last, size_t _maxAttempts, const Boundary *const _boundary, GroupOutputIterator _valid, GroupOutputIterator _invalid)
 
void Filter (GroupInputIterator _first, GroupInputIterator _last, size_t _maxAttempts, const Boundary *const _boundary, GroupOutputIterator _valid)
 This is an overloaded member function, provided for convenience. It differs from the above function only in what argument(s) it accepts. More...
 
- Public Member Functions inherited from MPBaseObject
 MPBaseObject (const std::string &_label="", const std::string &_name="", bool _debug=false)
 
 MPBaseObject (XMLNode &_node)
 
virtual ~MPBaseObject ()
 
virtual void Initialize ()
 
const std::string & GetName () const
 Get the class name for this object. More...
 
const std::string & GetLabel () const
 Get the unique label for this object. More...
 
std::string GetNameAndLabel () const
 Get the unique string identifier for this object "m_name::m_label". More...
 
void SetLabel (const std::string &)
 Set the unique label for this object. More...
 
void SetMPLibrary (MPLibrary *) noexcept
 Set the owning MPLibrary. More...
 
MPLibrary * GetMPLibrary () const noexcept
 Get the owning MPLibrary. More...
 
bool IsRunning () const noexcept
 Check the library's running flag. More...
 
MPProblem * GetMPProblem () const noexcept
 Get the library's current MPProblem. More...
 
Environment * GetEnvironment () const noexcept
 Get the current environment. More...
 
MPTask * GetTask () const noexcept
 Get the current task. More...
 
GroupTask * GetGroupTask () const noexcept
 Get the current group task. More...
 
MPSolutionType * GetMPSolution () const noexcept
 
RoadmapType * GetRoadmap (Robot *const _r=nullptr) const noexcept
 Get the current free-space roadmap. More...
 
GroupRoadmapType * GetGroupRoadmap (RobotGroup *const _g=nullptr) const noexcept
 Get the current free-space group roadmap. More...
 
RoadmapType * GetBlockRoadmap (Robot *const _r=nullptr) const noexcept
 Get the current obstacle-space roadmap. More...
 
Path * GetPath (Robot *const _r=nullptr) const noexcept
 
GroupPath * GetGroupPath (RobotGroup *const _g=nullptr) const noexcept
 Get the current best group path. More...
 
StatClass * GetStatClass () const noexcept
 Get the current StatClass. More...
 
LocalObstacleMap * GetLocalObstacleMap () const noexcept
 Get the local obstacle map. More...
 

Protected Member Functions

Helpers
virtual bool Sampler (Cfg &_cfg, const Boundary *const _boundary, std::vector< Cfg > &_result, std::vector< Cfg > &_collision)
 
virtual bool Sampler (GroupCfgType &_cfg, const Boundary *const _boundary, std::vector< GroupCfgType > &_result, std::vector< GroupCfgType > &_invalid)
 
virtual bool Sampler (GroupCfgType &_cfg, const BoundaryMap &_boundaryMap, std::vector< GroupCfgType > &_result, std::vector< GroupCfgType > &_collision)
 
void GenerateShells (const Boundary *const _boundary, Cfg &_cFree, Cfg &_cColl, Cfg &_incr, std::vector< Cfg > &_result, std::vector< Cfg > &_collision)
 
void GenerateShells (const Boundary *const _boundary, GroupCfgType &_cFree, GroupCfgType &_cColl, GroupCfgType &_incr, std::vector< GroupCfgType > &_result, std::vector< GroupCfgType > &_collision)
 
void GenerateShells (const BoundaryMap &_boundaryMap, GroupCfgType &_cFree, GroupCfgType &_cColl, GroupCfgType &_incr, std::vector< GroupCfgType > &_result, std::vector< GroupCfgType > &_collision)
 
Cfg ChooseCenterOfMass (MultiBody *_mBody)
 
Cfg ChooseRandomVertex (MultiBody *_mBody)
 
Vector3d ChoosePointOnTriangle (Vector3d _p, Vector3d _q, Vector3d _r)
 
Cfg ChooseRandomWeightedTriangle (MultiBody *_mBody)
 
Cfg ChooseRandomTriangle (MultiBody *_mBody)
 
Cfg ChooseExtremeVertex (MultiBody *_mBody)
 
virtual Cfg ChooseASample (Cfg &_cfg)
 
virtual GroupCfgType ChooseASample (GroupCfgType &_cfg)
 
Cfg ChooseASampleOtherMethods ()
 
Cfg GetCfgWithParams (const Vector3d &_v)
 
bool GroupInBounds (GroupCfgType &_groupCfg, const BoundaryMap &_boundaryMap)
 
bool GroupInBounds (GroupCfgType &_groupCfg, const Boundary *const _boundary)
 
- Protected Member Functions inherited from SamplerMethod
virtual bool Sampler (Cfg &_cfg, const Boundary *const _robotBoundary, const Boundary *const _eeBoundary, std::vector< Cfg > &_valid, std::vector< Cfg > &_invalid)
 
- Protected Member Functions inherited from MPBaseObject
void SetName (const std::string &_s)
 
const std::string & GetBaseFilename () const
 

Additional Inherited Members

- Protected Attributes inherited from MPBaseObject
bool m_debug
 Print debug info? More...
 

Detailed Description

Obstacle-based sampling.

OBPRM samples by pushing random configurations along a random ray until they change validity, keeping the best free configuration.

Todo:
Implement GetCenterOfMass function in the ChooseCenterOfMass class
Member Typedef Documentation

◆ BoundaryMap

typedef std::map<Robot*, const Boundary*> ObstacleBasedSampler::BoundaryMap

◆ GroupCfgType

Constructor & Destructor Documentation

◆ ObstacleBasedSampler() [1/2]

ObstacleBasedSampler::ObstacleBasedSampler ( string  _vcLabel = "",
string  _dmLabel = "",
int  _free = 1,
int  _coll = 0,
double  _step = 0,
bool  _useBBX = true,
string  _pointSelection = "cspace" 
)

◆ ObstacleBasedSampler() [2/2]

ObstacleBasedSampler::ObstacleBasedSampler ( XMLNode &  _node)

◆ ~ObstacleBasedSampler()

virtual ObstacleBasedSampler::~ObstacleBasedSampler ( )
virtualdefault

Member Function Documentation

◆ ChooseASample() [1/2]

Cfg ObstacleBasedSampler::ChooseASample ( Cfg &  _cfg)
protectedvirtual

Checks m_pointSelection and returns an appropriate Cfg

Parameters
_cfgConfiguration of the sample
Returns
Configuration of the sample

◆ ChooseASample() [2/2]

ObstacleBasedSampler::GroupCfgType ObstacleBasedSampler::ChooseASample ( GroupCfgType &  _cfg)
protectedvirtual

Checks m_pointSelection and returns an appropriate GroupCfgType

Parameters
_cfgGroup configuration of the sample
Returns
Group configuration chosen from the Extreme Vertex method

◆ ChooseASampleOtherMethods()

Cfg ObstacleBasedSampler::ChooseASampleOtherMethods ( )
protected

Call the various sample method other than cspace method

Returns
Configuration obtained according to the m_pointSelection

◆ ChooseCenterOfMass()

Cfg ObstacleBasedSampler::ChooseCenterOfMass ( MultiBody *  _mBody)
protected

Returns a Cfg at the center of mass of the MultiBody

Parameters
_mBodyMultibody of the obstacle
Returns
Configuration corresponding to the center of mass of the Multibody

◆ ChooseExtremeVertex()

Cfg ObstacleBasedSampler::ChooseExtremeVertex ( MultiBody *  _mBody)
protected

Chooses a random extreme vertex of the MultiBody

Parameters
_mBodyMultibody of the obstacle
Returns
Configuration chosen from the Extreme Vertex method

◆ ChoosePointOnTriangle()

Vector3d ObstacleBasedSampler::ChoosePointOnTriangle ( Vector3d  _p,
Vector3d  _q,
Vector3d  _r 
)
protected

Returns a point inside the triangle determined by the vectors

Parameters
_pThe first 3d point of a triangle
_qThe second 3d point of a triangle
_rThe Third 3d point of a triangle
Returns
Configuration chosen from the Point On Triangle method

◆ ChooseRandomTriangle()

Cfg ObstacleBasedSampler::ChooseRandomTriangle ( MultiBody *  _mBody)
protected

Chooses a random point in a random triangle in the MultiBody

Parameters
_mBodyMultibody of the obstacle
Returns
Configuration chosen from the Random Triangle method

◆ ChooseRandomVertex()

Cfg ObstacleBasedSampler::ChooseRandomVertex ( MultiBody *  _mBody)
protected
Parameters
_mBodyMultibody of the obstacle
Returns
Configuration chosen from the Random Vertex method

◆ ChooseRandomWeightedTriangle()

Cfg ObstacleBasedSampler::ChooseRandomWeightedTriangle ( MultiBody *  _mBody)
protected

Chooses a random point on a random triangle (weighted by area) in the MultiBody

Parameters
_mBodyMultibody of the obstacle
Returns
Configuration chosen from the Random Weighted Triangle method

◆ GenerateShells() [1/3]

void ObstacleBasedSampler::GenerateShells ( const Boundary *const  _boundary,
Cfg &  _cFree,
Cfg &  _cColl,
Cfg &  _incr,
std::vector< Cfg > &  _result,
std::vector< Cfg > &  _collision 
)
protected

Generates and adds shells to their containers for a single robot in a single boundary case

Parameters
_boundaryBoundary of the environment
_cFreeThe configuration in the Free Configuration Space
_cCollThe configuration in the Collision Configuration Space
_incrThe amount of increments in the specified direction.
_resultA vector that stores Free Configuration Space
_collisionA vector that stores Collision Configuration Space

◆ GenerateShells() [2/3]

void ObstacleBasedSampler::GenerateShells ( const Boundary *const  _boundary,
GroupCfgType &  _cFree,
GroupCfgType &  _cColl,
GroupCfgType &  _incr,
std::vector< GroupCfgType > &  _result,
std::vector< GroupCfgType > &  _collision 
)
protected

Generates and adds shells to their containers for multiple robots in a single boundary case

Parameters
_boundaryBoundary of the environment
_cFreeThe configuration in the Free Configuration Space
_cCollThe configuration in the Collision Configuration Space
_incrThe amount of increments in the specified direction.
_resultA vector that stores Free Group Configuration Space
_collisionA vector that stores Collision Group Configuration Space

◆ GenerateShells() [3/3]

void ObstacleBasedSampler::GenerateShells ( const BoundaryMap &  _boundaryMap,
GroupCfgType &  _cFree,
GroupCfgType &  _cColl,
GroupCfgType &  _incr,
std::vector< GroupCfgType > &  _result,
std::vector< GroupCfgType > &  _collision 
)
protected

Generates and adds shells to their containers for multiple robots in each individual boundary case

Parameters
_boundaryBoundary of the environment
_cFreeThe configuration in the Free Configuration Space
_cCollThe configuration in the Collision Configuration Space
_incrThe amount of increments in the specified direction.
_resultA vector that stores Free Group Configuration Space
_collisionA vector that stores Collision Group Configuration Space

◆ GetCfgWithParams()

Cfg ObstacleBasedSampler::GetCfgWithParams ( const Vector3d &  _v)
protected

Returns a Cfg with the coordinates specified in the vector and no rotation

Parameters
_vMultibody of the obstacle
Returns
Configuration Type of the sample

◆ GroupInBounds() [1/2]

bool ObstacleBasedSampler::GroupInBounds ( GroupCfgType &  _groupCfg,
const Boundary *const  _boundary 
)
protected

Checks if the groupCfg is in the boundary map

Parameters
_groupCfgThe group configuration needs to be checked
_boundaryThe single boundary of every robots
Returns
true or false

◆ GroupInBounds() [2/2]

bool ObstacleBasedSampler::GroupInBounds ( GroupCfgType &  _groupCfg,
const BoundaryMap &  _boundaryMap 
)
protected

Checks if the groupCfg is in the boundary map

Parameters
_groupCfgThe group configuration needs to be checked
_boundaryMapThe map that pairs each robot and corresponding boundary
Returns
true or false

◆ Print()

void ObstacleBasedSampler::Print ( ostream &  _os) const
overridevirtual

Print internal state of this object.

Parameters
_osThe std::ostream to print to.

Reimplemented from MPBaseObject.

◆ Sampler() [1/3]

bool ObstacleBasedSampler::Sampler ( Cfg &  _cfg,
const Boundary *const  _boundary,
std::vector< Cfg > &  _result,
std::vector< Cfg > &  _collision 
)
protectedvirtual

Main Sampler Sampler for a single robot in a single boundary

Parameters
_cfgConfiguration Type
_boundaryBoundary of the environment
_resultA vector that stores Free Configuration Space
_collisionA vector that stores Collision Configuration Space
Returns
Success or Failure of sampling

Reimplemented from SamplerMethod.

◆ Sampler() [2/3]

bool ObstacleBasedSampler::Sampler ( GroupCfgType &  _cfg,
const Boundary *const  _boundary,
std::vector< GroupCfgType > &  _result,
std::vector< GroupCfgType > &  _invalid 
)
protectedvirtual

Sampler for multiple robots in a single boundary

Parameters
_cfgConfiguration Type
_boundaryBoundary of the environment
_resultA vector that stores Free Group Configuration Space
_collisionA vector that stores Collision Group Configuration Space
Returns
Success or Failure of sampling

Reimplemented from SamplerMethod.

◆ Sampler() [3/3]

bool ObstacleBasedSampler::Sampler ( GroupCfgType &  _cfg,
const BoundaryMap &  _boundaryMap,
std::vector< GroupCfgType > &  _result,
std::vector< GroupCfgType > &  _collision 
)
protectedvirtual

Sampler for multiple robots in each individual boundary

Parameters
_cfgConfiguration Type
_boundaryMapBoundaryMap of the environment
_resultA vector that stores Free Group Configuration Space
_collisionA vector that stores Collision Group Configuration Space
Returns
Success or Failure of sampling

Reimplemented from SamplerMethod.


The documentation for this class was generated from the following files: